Industrial equipment. Informed decisions.8483454@gmail.com

Equipment category

Robotics & assembly
Buying guides & project requirements.

Define your application, required output and site conditions before comparing equipment proposals.

Clear filters

Showing 1–17 of 17 equipment guides.

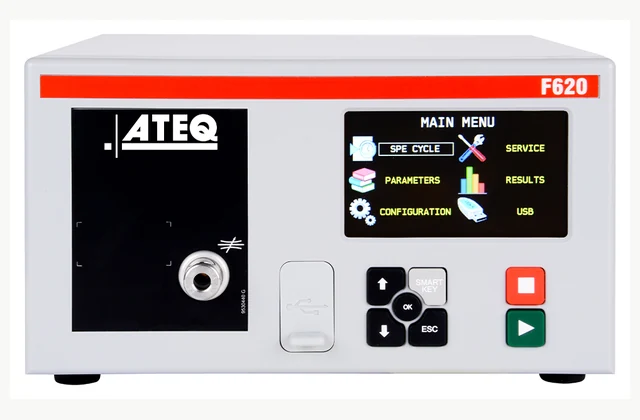
ATEQ F620 leak testing instrument for station integration actual equipment configuration reference
INDUSTRIAL AUTOMATION

Automated leak testing station

An automated leak testing station combines a measuring instrument with fixtures, sealing and part handling. The station verifies a specified leakage condition; it does not by itself prove every service-life failure mode. Start with part drawing and internal volume and test medium and pressure, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: ATEQ F620 leak testing instrument for station integration
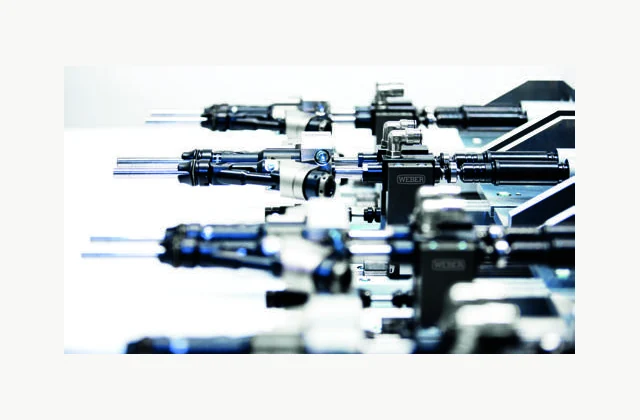
WEBER SBM25 blind rivet nut insertion system actual equipment configuration reference
INDUSTRIAL AUTOMATION

Automatic rivet insertion station

An automatic rivet insertion station feeds and positions a defined rivet into an assembly. Feeding, insertion and final joint formation may be separate operations and must be distinguished in the supply boundary. Start with rivet drawing and tolerances and rivet material and coating, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: WEBER SBM25 blind rivet nut insertion system

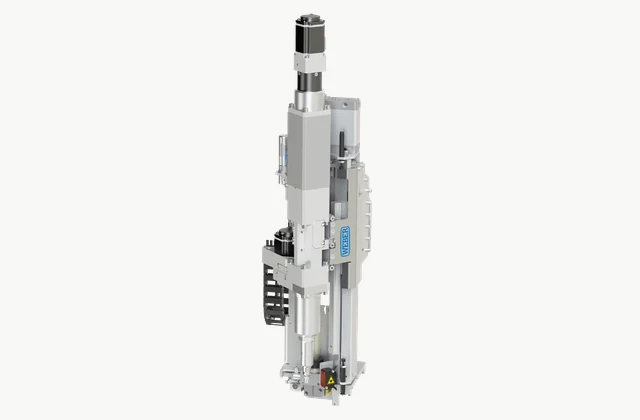
WEBER Automatic screwdriving spindle assembly actual equipment reference
INDUSTRIAL AUTOMATION

Automatic screwdriving system

An automatic screwdriving system feeds screws and tightens them into a controlled joint. The useful result is a verified fastening process, including presentation and reaction management, rather than spindle motion alone. Start with screw drawing and coating and joint materials and pilot hole, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: WEBER Automatic screwdriving spindle assembly

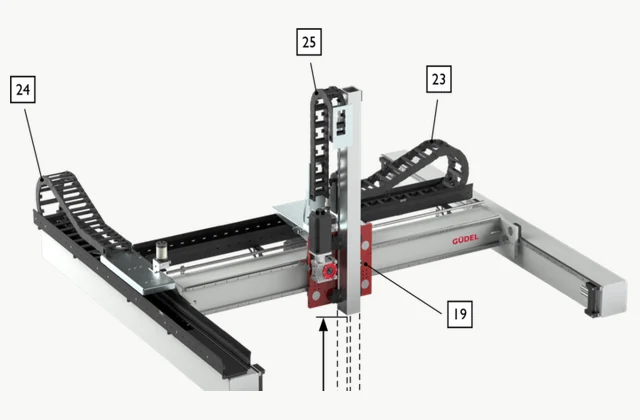
Güdel FP gantry robot actual equipment configuration reference
INDUSTRIAL AUTOMATION

Cartesian gantry robot

A Cartesian gantry robot moves a tool along linear axes over a defined work envelope. It suits structured transfers and large spans where support stiffness and installed alignment are central to repeatability. Start with payload with complete tooling and centre of gravity, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: Güdel FP gantry robot

FANUC DR-3iB/6 STAINLESS delta robot actual equipment configuration reference
INDUSTRIAL AUTOMATION

Delta robot

A delta robot uses parallel arms for rapid picking within a constrained working volume. The package combines robot motion with product presentation, vision and a suitable end effector. Start with product and gripper payload and pick and place geometry, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: FANUC DR-3iB/6 STAINLESS delta robot

Asyril Asycube 240 flexible feeder with hopper actual equipment reference
INDUSTRIAL AUTOMATION

Flexible vision feeder

A flexible vision feeder presents loose components on a programmable moving surface so vision and a robot can select correctly oriented pieces. It differs from a dedicated track that mechanically forces every part into one orientation. Start with component drawings and samples and part variants and finish, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: Asyril Asycube 240 flexible feeder with hopper

ATI QC-21 robotic tool changer actual equipment configuration reference
INDUSTRIAL AUTOMATION

Robot tool changer

A robot tool changer allows a robot-side master to couple with different tool-side plates. Mechanical retention, service transfer and verified locking together determine whether automatic changeover is practical. Start with complete tool masses and centres of gravity and moments, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: ATI QC-21 robotic tool changer

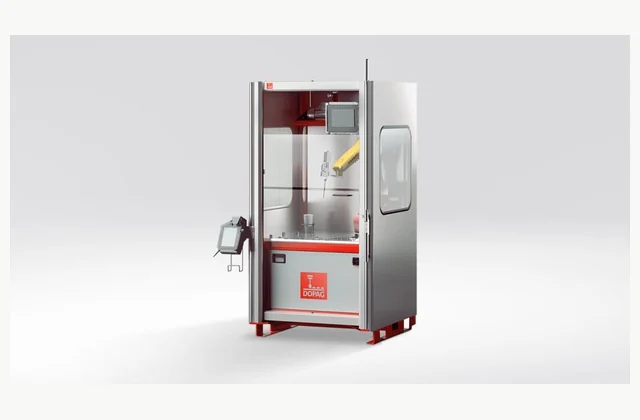
DOPAG multifunctional robot-assisted adhesive dispensing cell actual manufacturer design
INDUSTRIAL AUTOMATION

Robotic adhesive dispensing cell

A robotic adhesive dispensing cell coordinates a motion system and metering equipment to apply a controlled bead or deposit. The process includes material preparation and curing requirements, not just a repeatable path. Start with adhesive chemistry and data and viscosity and working time, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: DOPAG Multifunctional robot-assisted adhesive dispensing cell

ATI Axia80-M50 force torque sensor actual equipment configuration reference
INDUSTRIAL AUTOMATION

Robotic force torque sensor

A robotic force torque sensor measures forces and moments at a robot or tool interface. It enables contact feedback, but the resulting process still depends on calibration, control behaviour and mechanical stiffness. Start with force and torque envelope and required signal resolution, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: ATI Axia80-M50 force torque sensor

FANUC ROBODRILL machine tending application actual equipment configuration reference
INDUSTRIAL AUTOMATION

Robotic machine tending system

A robotic machine tending system loads and unloads a machine while coordinating doors, workholding and process status. The cell must manage chips, part variation and recovery as part of the production sequence. Start with raw and finished part drawings and grip zones and burrs, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: FANUC ROBODRILL machine tending application

Liebherr and Zivid LHRobotics 3D vision bin picking cell design reference actual equipment configuration reference
INDUSTRIAL AUTOMATION

Robotic random bin picking system

A random bin picking system uses three-dimensional sensing and robot motion planning to select parts from unstructured piles. The engineering problem includes graspability, collision avoidance and recovery of remaining difficult pieces. Start with part geometry and finish and bin dimensions and variation, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: Liebherr and Zivid LHRobotics 3D vision bin picking cell design reference

FANUC SR-3iA SCARA robot actual equipment configuration reference
INDUSTRIAL AUTOMATION

SCARA robot

A SCARA robot provides planar articulated motion with a vertical axis for structured assembly and transfer. Its suitability depends on insertion direction, reach and wrist loading within the actual cell. Start with tool and part payload and reach and work coordinates, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: FANUC SR-3iA SCARA robot

Kistler NC joining system actual equipment configuration reference
INDUSTRIAL AUTOMATION

Servo electric assembly press

A servo electric assembly press applies programmable joining motion and records the force-displacement response. The useful result is a validated joint, not simply a commanded force at the end of travel. Start with joint and interference drawings and part and lubrication variation, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: Kistler NC joining system

RNA Conventional vibratory bowl feeder actual equipment configuration reference
INDUSTRIAL AUTOMATION

Vibratory bowl feeder

A vibratory bowl feeder uses a shaped track and controlled vibration to orient and deliver discrete components. Tooling is tied to a part family; a similar-looking component can feed differently. Start with component drawing and samples and surface finish and oil, then agree the configuration and the evidence required for acceptance.

Explore the buying guide

Reference: RNA Conventional vibratory bowl feeder

Build a comparable request

Start with the work your equipment needs to do.

Share the application, required output, destination, utilities, quantities and planned timing. For OEM / ODM projects, include the branding, configuration or engineering changes, sample approval and acceptance requirements.

Practical buying decisions

Guides for this equipment category.

More buying guides ↗
Industrial automation

Vibratory bowl feeder: RFQ Checklist and Quotation Review

A comparable vibratory bowl feeder quotation starts with component drawing and samples, surface finish and oil, required exit orientation. Record the required result, site interfaces and acceptance evidence in one revision-controlled RFQ. IndustryApex engineers use these inputs to define the equipment, integration and OEM/ODM scope…

RFQ & acceptance · 4 min read
Read the guide
Industrial automation

Servo electric assembly press: RFQ Checklist and Quotation Review

A comparable servo electric assembly press quotation starts with joint and interference drawings, part and lubrication variation, seating depth and force envelope. Record the required result, site interfaces and acceptance evidence in one revision-controlled RFQ. IndustryApex engineers use these inputs to define the equipment, integration…

RFQ & acceptance · 4 min read
Read the guide
Industrial automation

SCARA robot: RFQ Checklist and Quotation Review

A comparable SCARA robot quotation starts with tool and part payload, reach and work coordinates, vertical stroke. Record the required result, site interfaces and acceptance evidence in one revision-controlled RFQ. IndustryApex engineers use these inputs to define the equipment, integration and OEM/ODM scope for your…

RFQ & acceptance · 4 min read
Read the guide
WhatsApp